When the Greenhouse Starts Listening
Natural-language robotics could make human expertise scalable in agriculture. The real test is whether tacit agronomic judgment can become safe, traceable and accountable machine action.
At first sight, language-controlled greenhouse robots look like a new interface: the expert speaks, the machine understands and the work gets done.
The more consequential change is different. Language is becoming physical action.
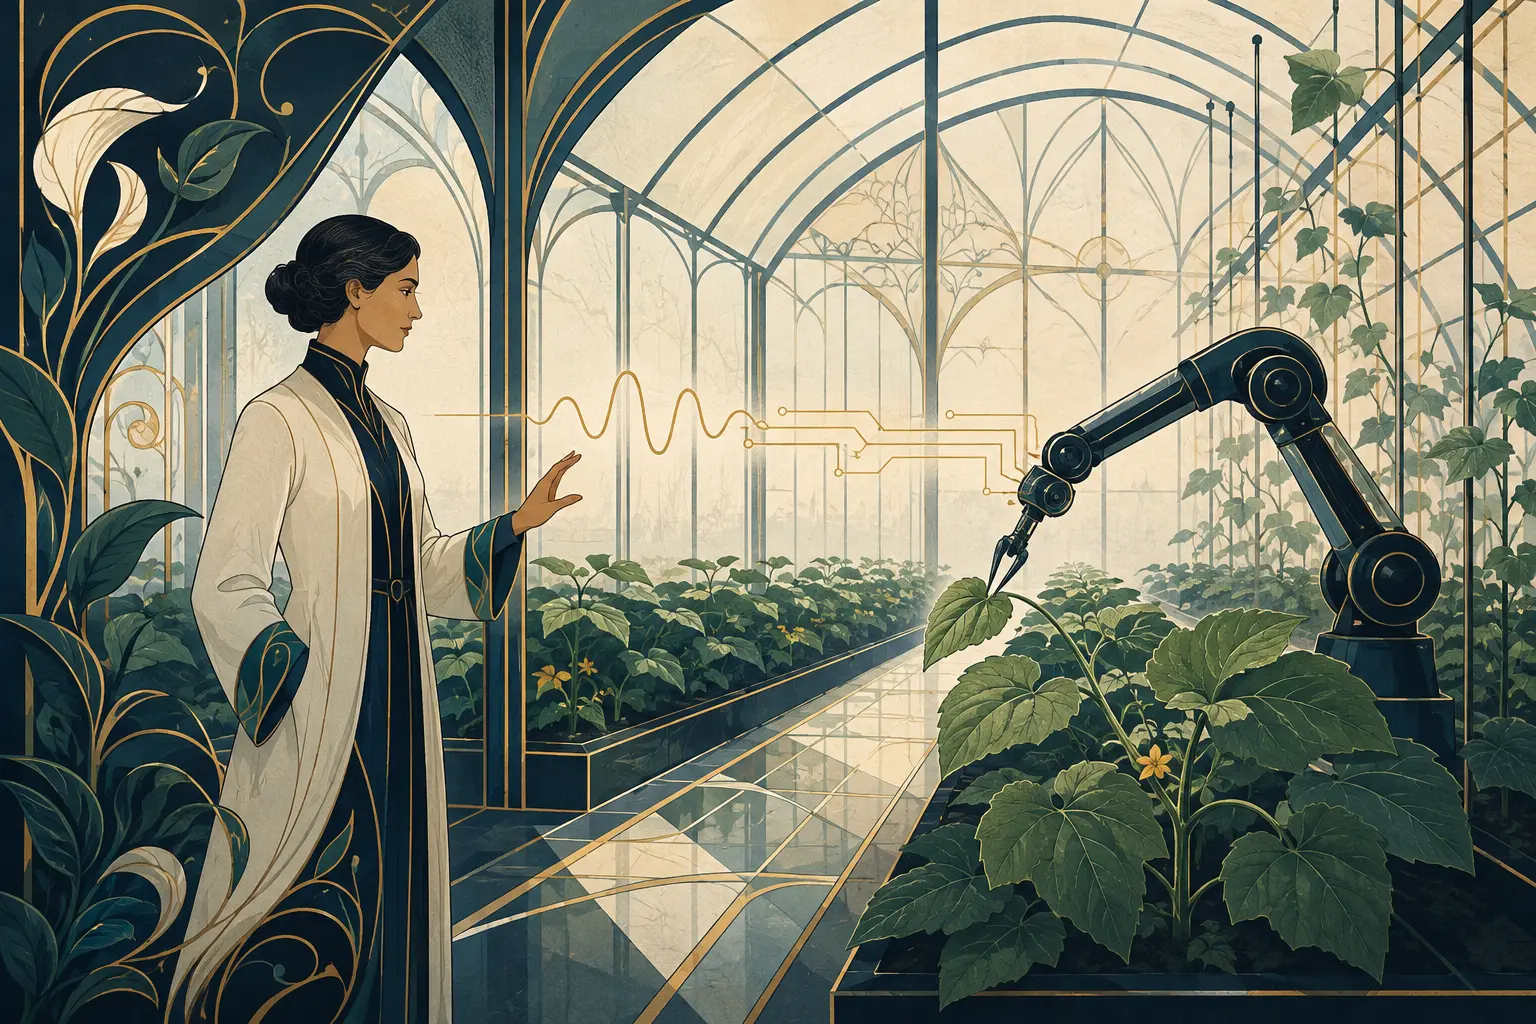
The AgriLoop project, led by the University of Bonn with partners in Taiwan, is exploring precisely that transition. It combines language and multimodal AI, 3D perception and embedded robotics so that an agricultural expert can inspect plants, issue natural-language instructions and correct the robot’s behaviour. The Bonn work has received €463,000 in German federal funding, and the project aims to produce a practical demonstrator.
From instruction to intervention
“Remove this leaf” sounds like a command. In reality, it is compressed professional judgment.
Which leaf? For what reason? How much force is safe? What if another stem blocks the movement? How certain must the system be before acting?
A human worker often resolves these questions without stating them. A robot cannot. It has to connect language to the right plant, locate the relevant object in three dimensions, select a movement and execute it without harming the crop.
AgriLoop’s significance lies in linking those stages. Once an AI output moves a machine, however, error changes category. A mistaken answer is no longer only text on a screen. It can become a damaged plant, an unsafe movement or a flawed intervention repeated at scale.
“Human in the loop” is not a governance model by itself
The phrase is reassuring, but it can describe very different systems.
In one, the expert remains meaningfully in control: the robot exposes uncertainty, requests clarification, records the instruction and allows intervention before an irreversible action. In another, the human merely confirms a recommendation too quickly to assess it.
The difference is architecture.
A workable system needs clear rules on when approval is required, what the robot may do autonomously, how corrections alter later behaviour and what record distinguishes the advice given from the action executed.
There is a deeper tension. Human expertise is valuable because it is contextual. Yet that same quality makes it difficult to standardise. If an expert’s correction becomes training data, who decides whether a local judgment should become general machine behaviour? Feedback can improve performance. It can also scale a mistake.
From smart prototype to trusted infrastructure
The practical case is strong. Europe faces skilled-labour shortages, increasingly complex greenhouse operations and pressure to use water, energy and crop-protection inputs more precisely. A robot able to monitor routinely and intervene selectively could allow scarce expertise to supervise a much larger production area.
AgriLoop’s work on efficient models that can run on robot platforms is equally important. Agricultural automation cannot depend indefinitely on permanent access to remote, energy-intensive data centres.
But a convincing demonstrator is only the beginning. Adoption will depend on trust, evidence and responsibility: reliable action logs, defined operating limits, effective stop mechanisms, agronomic validation and a clear allocation of responsibility when instruction, interpretation and execution diverge.
These questions are easier to design into a system than to bolt onto it later.
AgriLoop begins with a deceptively simple ambition: make the greenhouse robot understand the expert. The larger project is to build a credible translation layer between tacit knowledge and automation.
Done well, that could preserve human agency while making expertise more scalable. Done badly, the human risks becoming the last click before the machine acts.
Four questions worth debating
- When should a greenhouse robot be required to ask for clarification rather than act?
- Which agricultural decisions should remain non-delegable, even when automation becomes technically reliable?
- Who should control the correction data—and the machine competence derived from it?
- At what point does an experimental assistant become production infrastructure, and who must prove that it remains safe as it learns?
Source: University of Bonn, “Robots Listening Out for Instructions,” 24 August 2026.
Discuss the implications for your file.
First conversations are exploratory and without obligation.
Contact Nexum